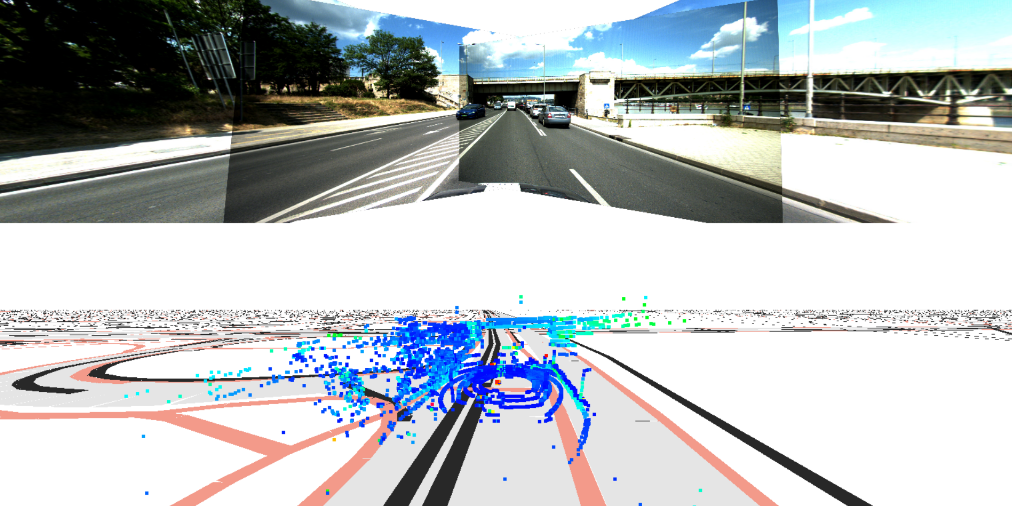
Our colleagues have published a paper at GRAFGEO2024 which overviews how ELTECar can be applied to save traffic situations recorded by different vehicle-mounted sensors.  

A client-server approach for MS Windows has been developed. You can download the client and server if you click on the links. 

Server:

Example client:

Data can be found using the links at https://www.hackademix.hu/timeline-of-the-contest/. The server can load these files.

Explore More

Exploring 3D Vision: Inside Our R&D Lab at ELTE

We are excited to share a video showcasing the recent research and development work of the Geometric Computer Vision Group at Eötvös Loránd University (ELTE). 🎥 In this short overview,

New Open-Source Release: AffineExtractor Toolbox

We are pleased to announce the public release of AffineExtractor, a new Python-based computer vision toolbox developed by our research group. The repository is now available on GitHub for the

New BMVC Paper: Calibration of 2D LiDAR Sensors Using Cylindrical Target

Tamás Tófalvi, PhD student of our research group presented the work entitled ‘Calibration of 2D LiDAR sensors using cylindrical target’, written by Tófalvi Tamás, Bandó Kovács, and Levente Hajder. Abstract: