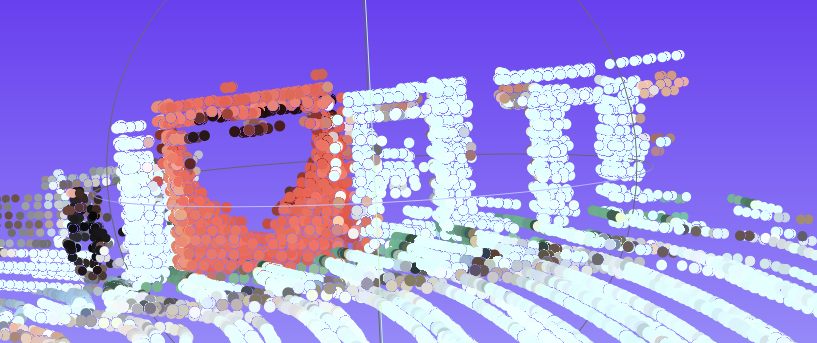
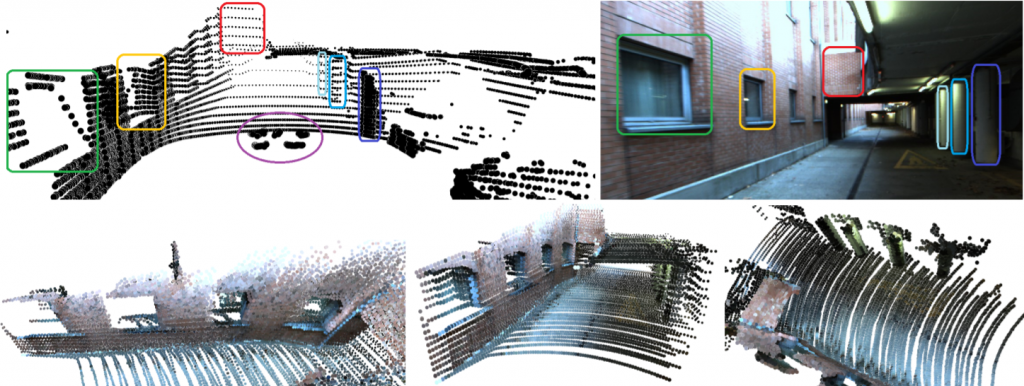
Autóra szerelt kamerák lépeiből, és LiDAR adatokból rekonstruált jelenetek.
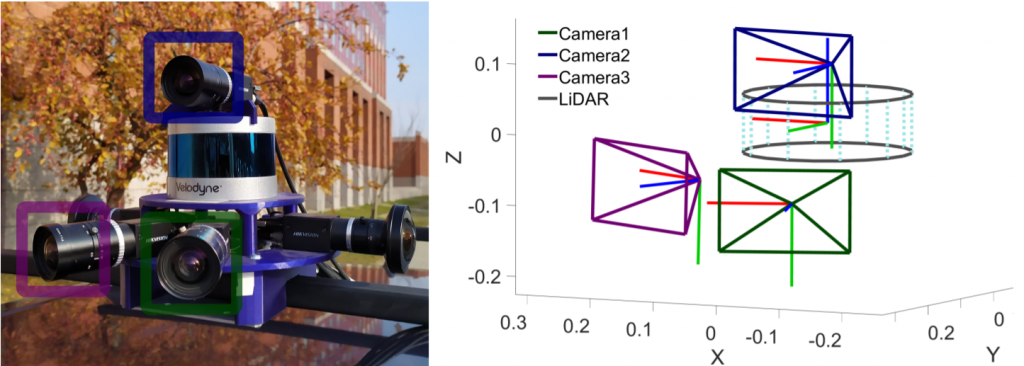
LiDAR és kamerák helyzete egymáshoz képest:
A készülő cikk kézirata: IJCV manualscript
Autóra szerelt kamerák lépeiből, és LiDAR adatokból rekonstruált jelenetek.
LiDAR és kamerák helyzete egymáshoz képest:
A készülő cikk kézirata: IJCV manualscript
Congratulations to Tarlan Ahadli, PhD student of our research group, to who was awarded the ‘Best Talk of the Image Processing’ price at the Conference of PhD Students in Computer
The result of the first Bosch-ELTE competition is as follows: 1) Barbara Szabó 2) Dávid Fischer 3) Bence Csabai Congratulations for the students. The original proposal can be read here:
We have a novel paper, accepted for ICCV2023. Authors: Levente Hajder, Lajos Lóczi, Daniel Barath Abstract We present a new solver for estimating a surface normal from a single affine