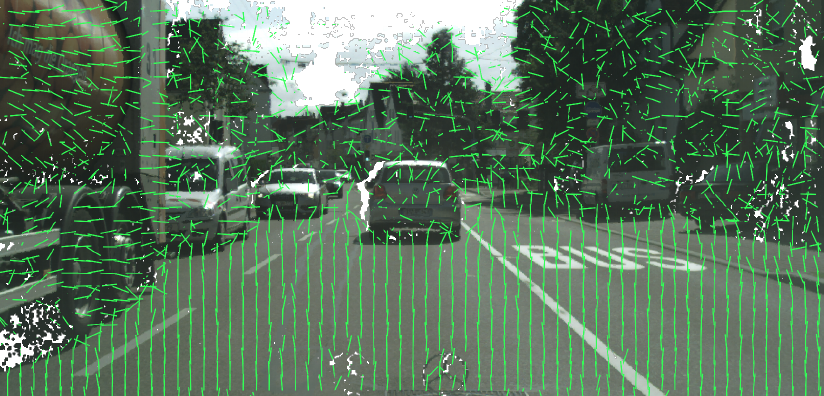
We are thrilled to announce that our latest research, “Robust and Real-time Surface Normal Estimation from Stereo Disparities using Affine Transformations”, was successfully presented at the prestigious ICRA 2026 conference in Vienna. Our colleague, Levente Hajder, showcased the poster detailing this collaborative work, authored alongside Csongor Csanád Karikó and Muhammad Rafi Faisal from the Geometric Computer Vision Group at Eötvös Loránd University. The paper addresses a crucial challenge in computer vision and robotics: the rapid and accurate generation of oriented point clouds.
he novel method introduced by our team leverages affine transformations derived directly from disparity values in rectified stereo image pairs, a technique that significantly reduces computational complexity. To ensure both high speed and robustness against noise, the approach utilizes a custom algorithm inspired by convolutional operations , paired with adaptive heuristic techniques to efficiently detect connected surface components. Validated on the Middlebury and Cityscapes datasets, this purely geometric, GPU-powered solution achieves real-time performance and significantly outperforms traditional PCA-based normal estimation methods in both speed and accuracy.